Why a Symptom-First Approach Saves Downtime
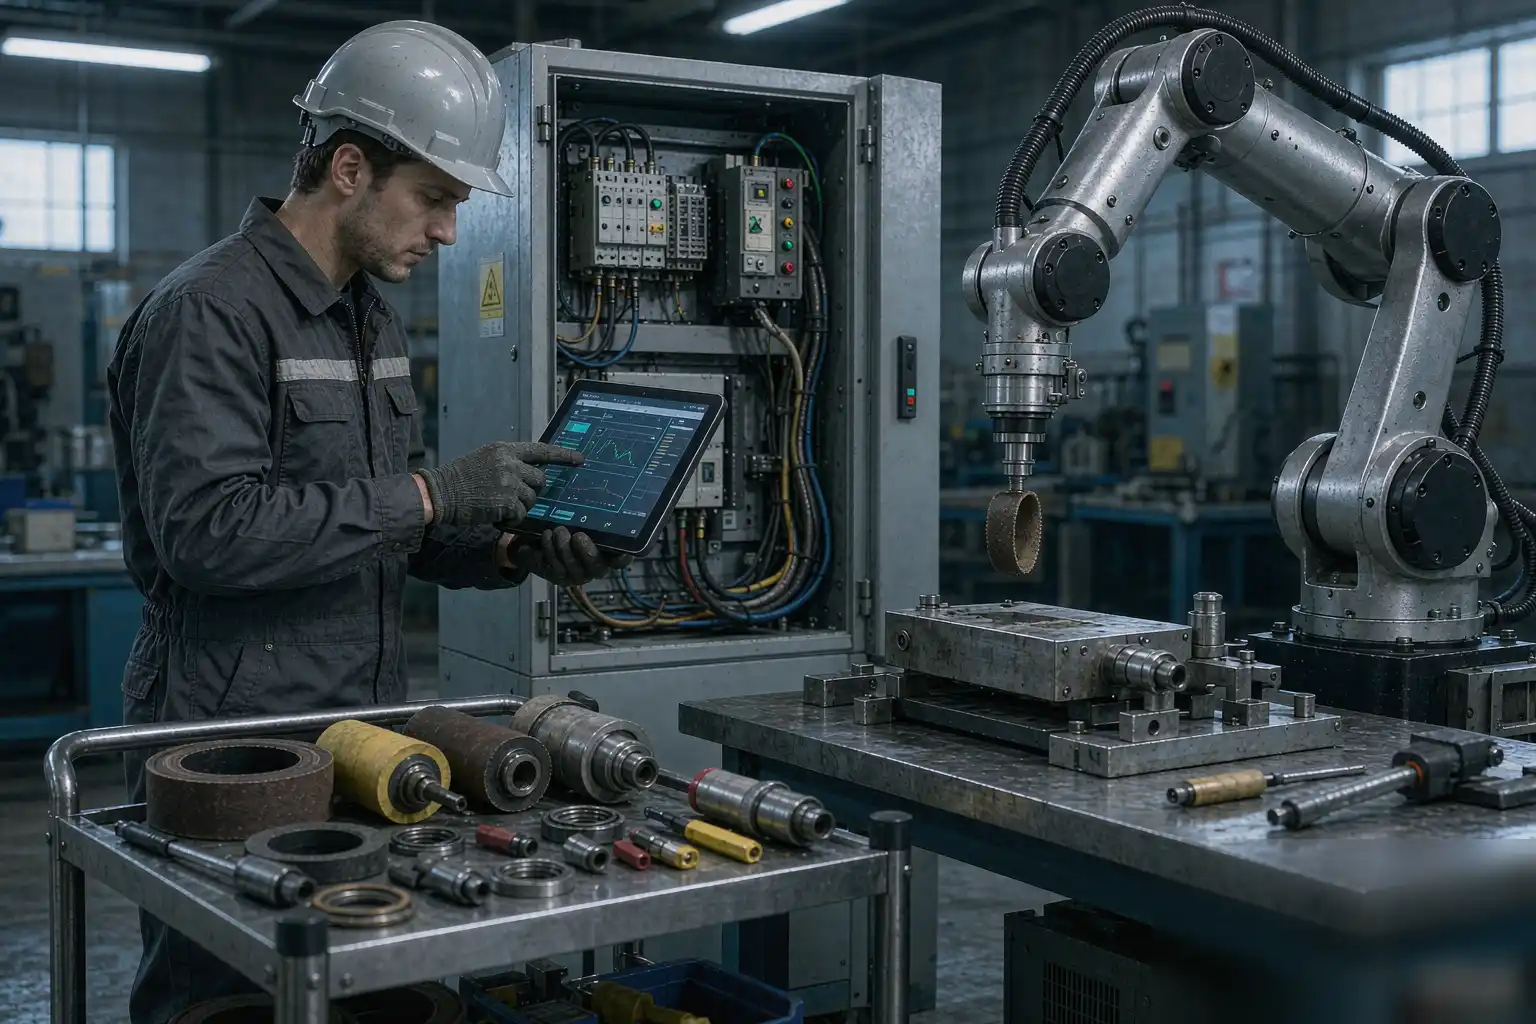
Robotic finishing troubleshooting begins with a disciplined, symptom-first mindset. When a cell starts producing rejects, engineers must isolate the single most likely variable before changing parameters. This catalogue maps the most common symptoms to their root causes and the fastest verified fixes drawn from production cells. Each entry follows the same shape: observe the defect, confirm the mechanism, apply the minimum change that restores the process. Keep it at the workstation as a field reference, and review it alongside our grinding machine maintenance tips for maximum uptime to prevent most failures before they start.
Inconsistent Surface Finish Across Parts
The first red flag in robotic finishing troubleshooting is finish drift from one part to the next. Often this stems from abrasive media that has worn past its effective window without compensation. Verify belt or flap-wheel wear, then confirm the force setpoint has not drifted after a recent program edit. Recalibrate the contact force and re-run a five-part sample before resuming full production. Document the wear stage at which drift begins so the team can schedule media changes proactively rather than reactively.
SYMPTOM — Finish looks acceptable on the first part but degrades or varies by part three onward.
Chatter Marks and Vibration
Chatter appears as regular ripples parallel to the tool path and signals a resonance problem. Check that the robot is not moving at the resonant speed band for the spindle and arm combination. Lower the feed rate by ten percent and increase spindle RPM slightly to break the standing wave. If chatter persists, inspect the tool holder for runout above 0.02 mm. Also confirm the arm is not near a fully extended pose, where stiffness drops and vibration couples into the part more readily than near the base.
Premature Abrasive Belt Wear
Belts that tear or glaze far ahead of their rated life usually indicate excessive downforce or wrong grit for the material. Reduce contact force in two-newton increments and confirm the platen is flat and free of embedded debris. Switching to a coarser entry grit for rough passes often doubles total belt life. A simple wear log helps the team spot when a supplier batch has shifted in quality. Remember that coolant type also matters; a belt rated for dry use will load quickly once mist is introduced, so match the media to the wet or dry process.
Burn Marks on the Workpiece
Burning means heat is building faster than the process can shed it. The fastest fix is to raise feed speed or lower spindle load so each point spends less time under the wheel. Confirm coolant delivery is actually reaching the contact zone, not just dripping nearby. For heat-sensitive alloys, add a second light finishing pass instead of one aggressive cut. Discolored heat tint is reversible only in the mildest cases, so treat burning as a defect to prevent rather than a finish to repair after the fact.
Path Deviations and Programming Errors
When the tool marks wander from the taught path, suspect encoder backlash or a loose master fixture. Run a no-load teach replay and compare the traced path to the original program frame. Tighten any worn wrist bearings and re-home the cell. Small deviations compound over a shift, so catch them early with a daily first-article check. If the drift correlates with robot temperature, allow a warm-up cycle before production because arm geometry shifts slightly until bearings reach operating temperature. Many “machine faults” are also teach-point mistakes rather than hardware problems. A single mis-keyed offset shifts every part by the same error, which is easy to miss without a reference artifact. Re-verify the base frame against a calibrated datum block after any program merge, and keep a read-only golden program so operators restore quickly instead of patching live. Version every program change with a short note on what and why, because undocumented tweaks are the fastest way to lose the known-good baseline during a frantic recovery.
Excessive Force and Dwell Issues
Over-force dents soft castings and strips delicate edges. Modern cells use active force control, but a mis-scaled analog signal can double the commanded load. Re-zero the force sensor against a known deadweight and confirm the gain in the controller. Then shorten dwell at corners where most material is removed unintentionally. A force trace captured during a good part is the best baseline; compare every shift’s first article against it to catch gain drift before it ruins a batch.
Poor Edge Break and Burr Removal
Incomplete deburring usually means the tool approaches the edge at the wrong angle. Teach the path so the abrasive meets the edge tangentially rather than head-on. For parts with variable burr size, add a vision step that classes burr height and selects a stronger pass only where needed. This avoids over-processing clean edges while still clearing the stubborn ones. Consistent edge break also depends on the burr being on the same side every time, so verify the upstream cutting process before tuning the robot further.
Coolant and Dust Collection Problems
Robotic finishing troubleshooting frequently uncovers poor housekeeping as the hidden cause. Clogged mist filters starve the collector and let dust recirculate onto fresh surfaces. Empty sumps on schedule and verify static pressure at the hood. A clean air path protects both finish quality and the robot’s internal optics from abrasive contamination.
- Check filter differential pressure weekly and log the reading.
- Verify coolant concentration with a refractometer, not by color alone.
- Inspect ducting for packed fines after any new alloy is introduced.
- Confirm the separator removes swarf before it reaches the pump.
Spindle Overheating
A spindle that trips on thermal fault is losing lubrication or fighting excess radial load. Feel the housing after a short run; a hot nose points to bearing wear, while even heat suggests ambient or duty overload. Reduce pass depth and confirm the air curtain is sealing the bearing cavity. Replace grease on the manufacturer interval rather than waiting for failure. Track spindle current draw over time as well; a slow upward trend at fixed load is an early warning that bearings are aging long before any alarm sounds.
Part Fixturing and Clamping Errors
Movement of the part under load creates ghost defects that look like tool problems. Confirm locating pins are not worn and that clamp torque matches the work instruction. For thin-walled parts, add a compliant support beneath the contact zone to stop flex. A rigid, repeatable fixture is the cheapest upgrade in any finishing cell. Mark the fixture’s datums and re-qualify them monthly, because a fixture that has crept a few tenths will reproduce the same ghost defect on every part it holds.
Sensor and Force Feedback Failures
When force control reports nonsense, the cell either over- or under-presses and scrap climbs. First check the cable for repeated flex fatigue at the wrist, the most common break point. Swap in a known-good sensor to isolate hardware from calibration. Then re-run the zero routine with the tool clear of any surface. If the noise disappears only when the arm is still, the fault is almost certainly the cable rather than the sensor electronics, which saves a needless component swap.
SYMPTOM — Force readout jumps or flatlines during a pass that should be steady.
Cell Throughput Bottlenecks
Slow cycle time is rarely the robot’s fault; it is usually the waiting. Map the cell and you will often find loading, coolant warm-up, or inspection eating the gains. Balancing the line and adding a second fixture station recovers hours per shift. Facilities that automate for scale also gain from automated surface polishing to reduce labor costs by reallocating skilled labor to higher-value tasks.
Safety Interlocks Tripping Repeatedly
Nuisance e-stops waste more time than real faults. Inspect door switches for misalignment and light curtains for drift in their detection window. Clean the lenses and confirm the muting logic matches the current cell layout. A log of trip causes quickly reveals whether the issue is hardware, programming, or operator habit. Before bypassing any interlock to “keep the line running,” stop and fix the root cause, because defeated safety devices turn a minor jam into a serious injury risk.
Keeping Pace With New Process Technology
Finally, troubleshooting is easier when the cell itself is modern and observable. Adaptive force control, in-process metrology, and self-compensating tools remove whole classes of defects discussed above. Teams planning a refresh should study the latest industrial surface finishing technologies in 2026 to choose capabilities that match their defect profile. Investing in diagnostics upfront turns unpredictable breakdowns into scheduled, minor adjustments.
Building a Troubleshooting Routine That Sticks
The best robotic finishing troubleshooting is the routine you actually follow, not the manual on the shelf. Assign one owner per cell, keep the triage table laminated at the station, and review top defects in the weekly standup. Over a few months the same failures stop recurring because the team now catches them at the first symptom. That discipline, more than any single fix, is what keeps a finishing cell profitable.
Use the triage card below as a fast reference when the line is down. Match the symptom, then confirm the cause before applying the fix so you do not mask a deeper issue. This is the practical core of robotic finishing troubleshooting on a busy floor.
| Issue | Likely Cause | Fix |
|---|---|---|
| Finish drift between parts | Worn abrasive, force drift | Recalibrate force, replace media |
| Chatter ripples | Resonance at feed speed | Lower feed 10%, check runout |
| Burn marks | Heat buildup, low coolant | Raise feed, verify coolant aim |
| Force sensor noise | Wrist cable fatigue | Swap sensor, re-zero |
Safety and guarding requirements vary by region — follow local codes and OEM guidance.